Micah Mok
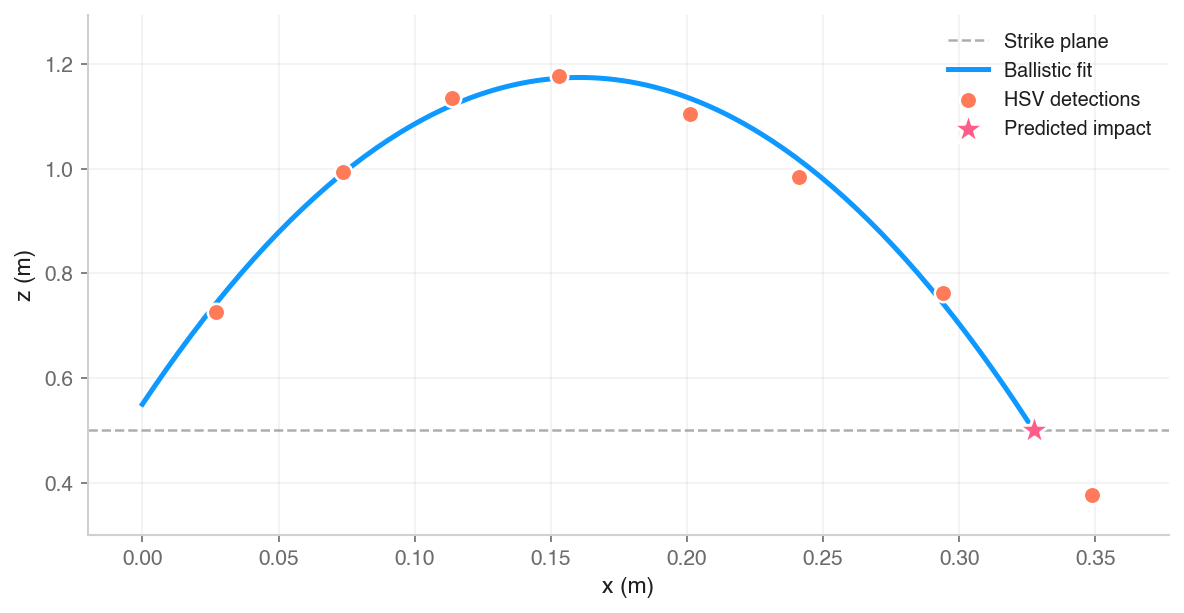
Micah is a senior in Cognitive Science and Computer Science. He's excited to graduate and explore the world. He worked on the trajectory prediction, and portions of the planning and control pipeline.
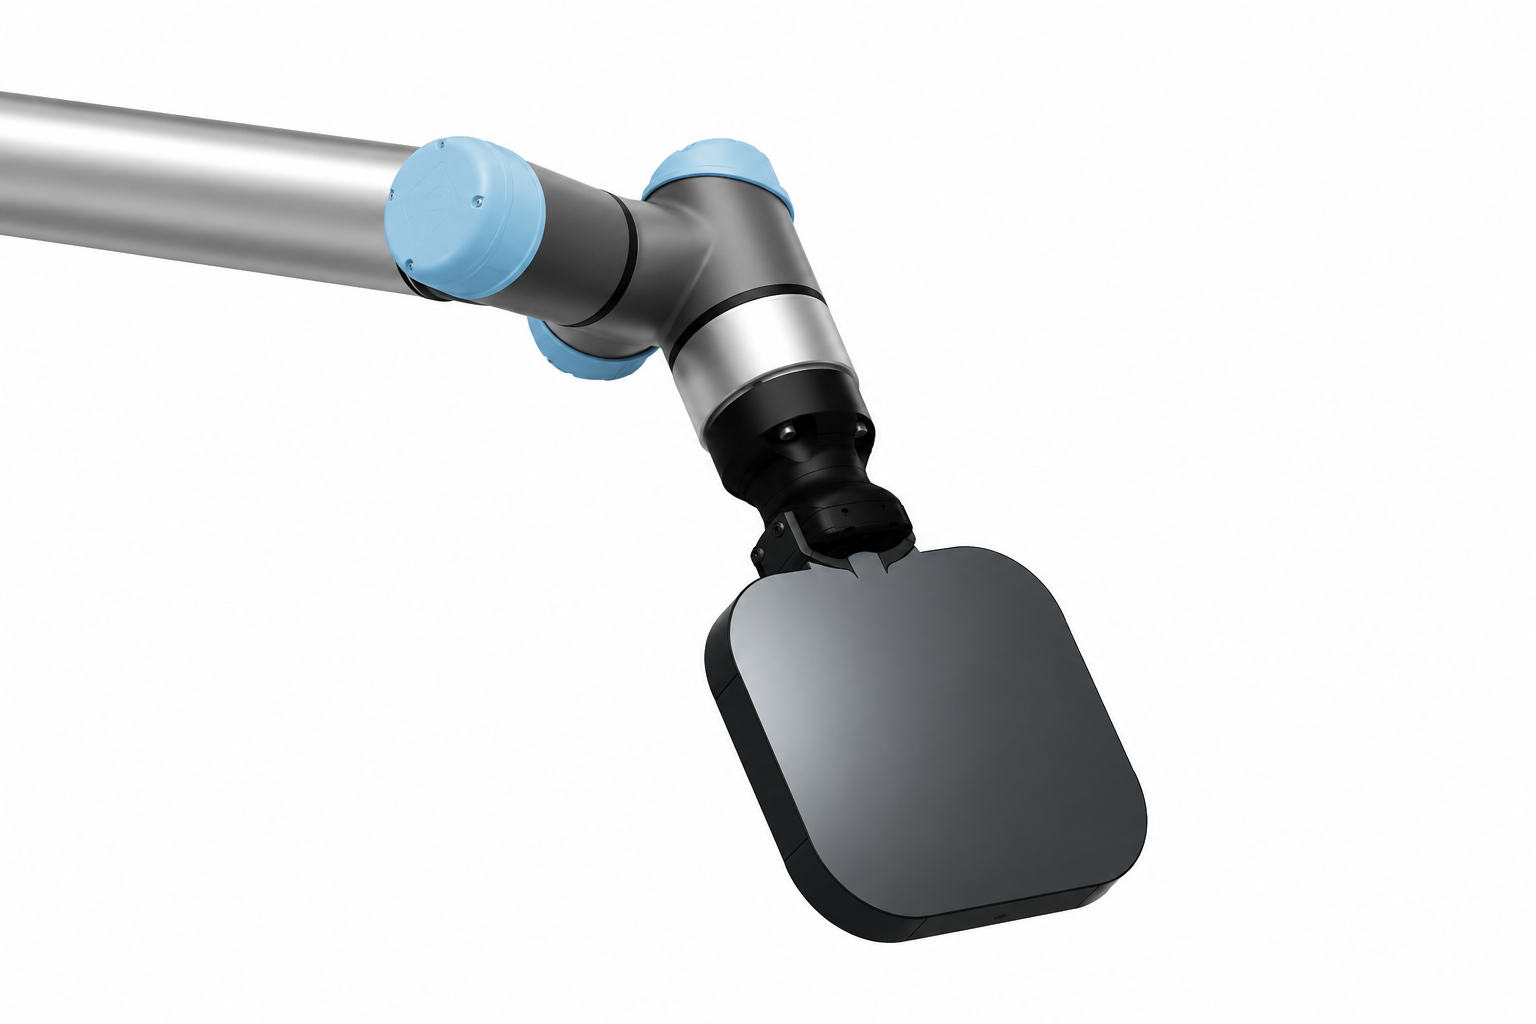
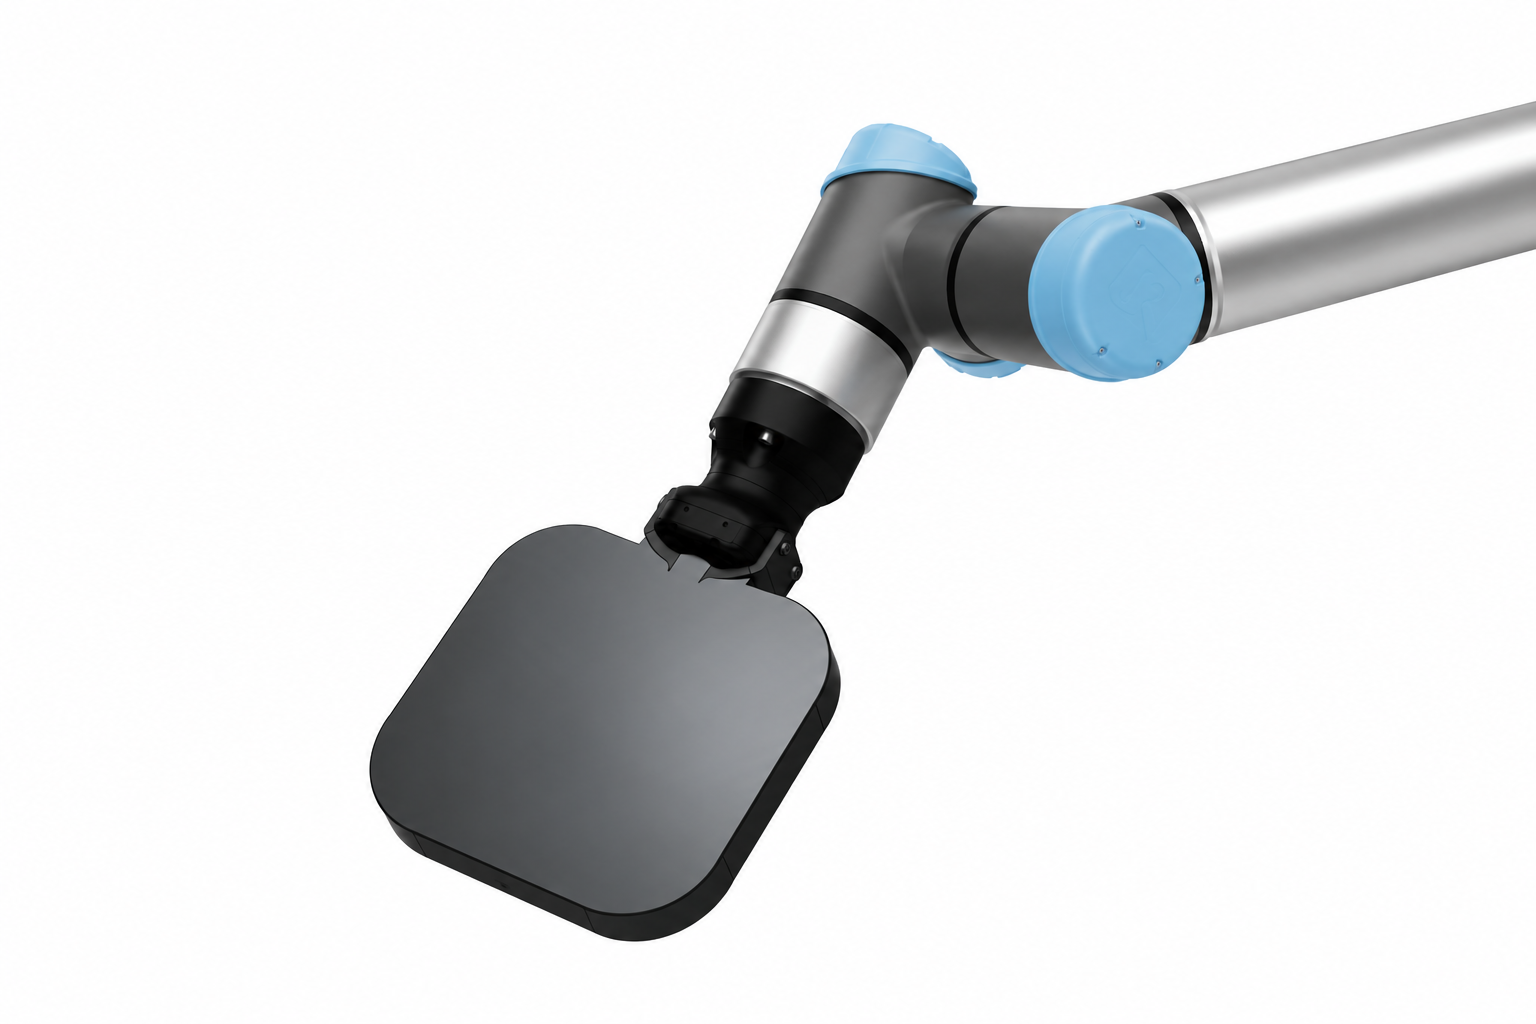
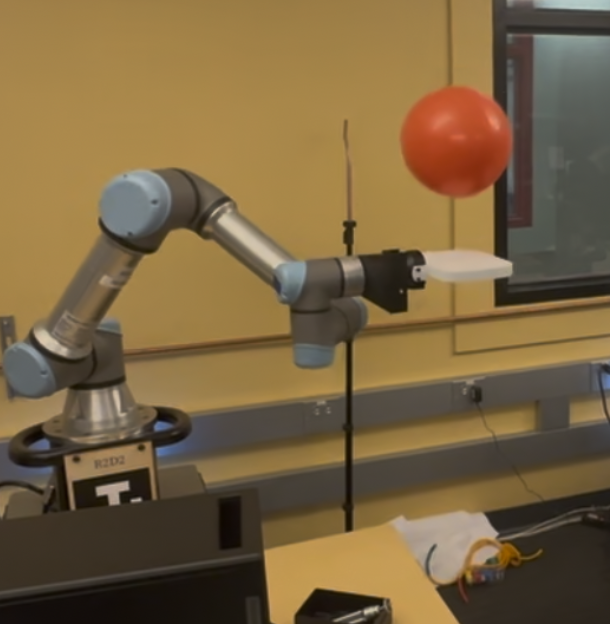
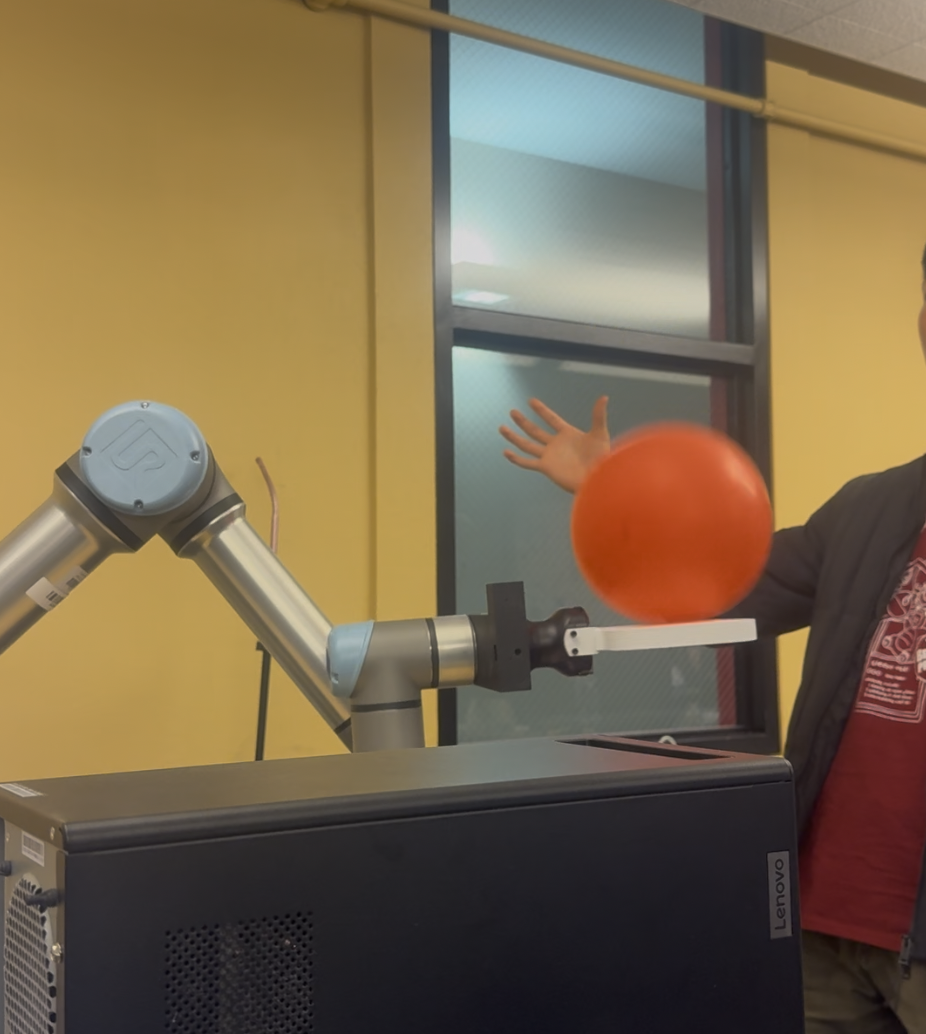
Our goal was to combine control, perception and planning
to control a robot arm to repeatedly bounce
a balloon or ball.
Micah is a senior in Cognitive Science and Computer Science. He's excited to graduate and explore the world. He worked on the trajectory prediction, and portions of the planning and control pipeline.
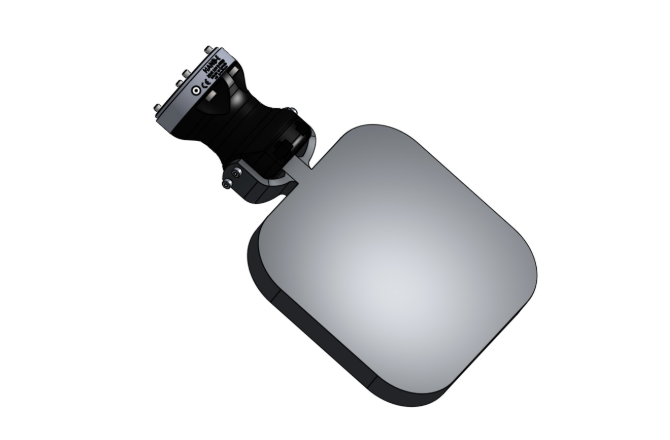
Indy is a junior EECS student. In her spare time, she likes building matcha making robots. Worked on the end-effector design, perception, portions of the control / planning pipeline, and helping test.
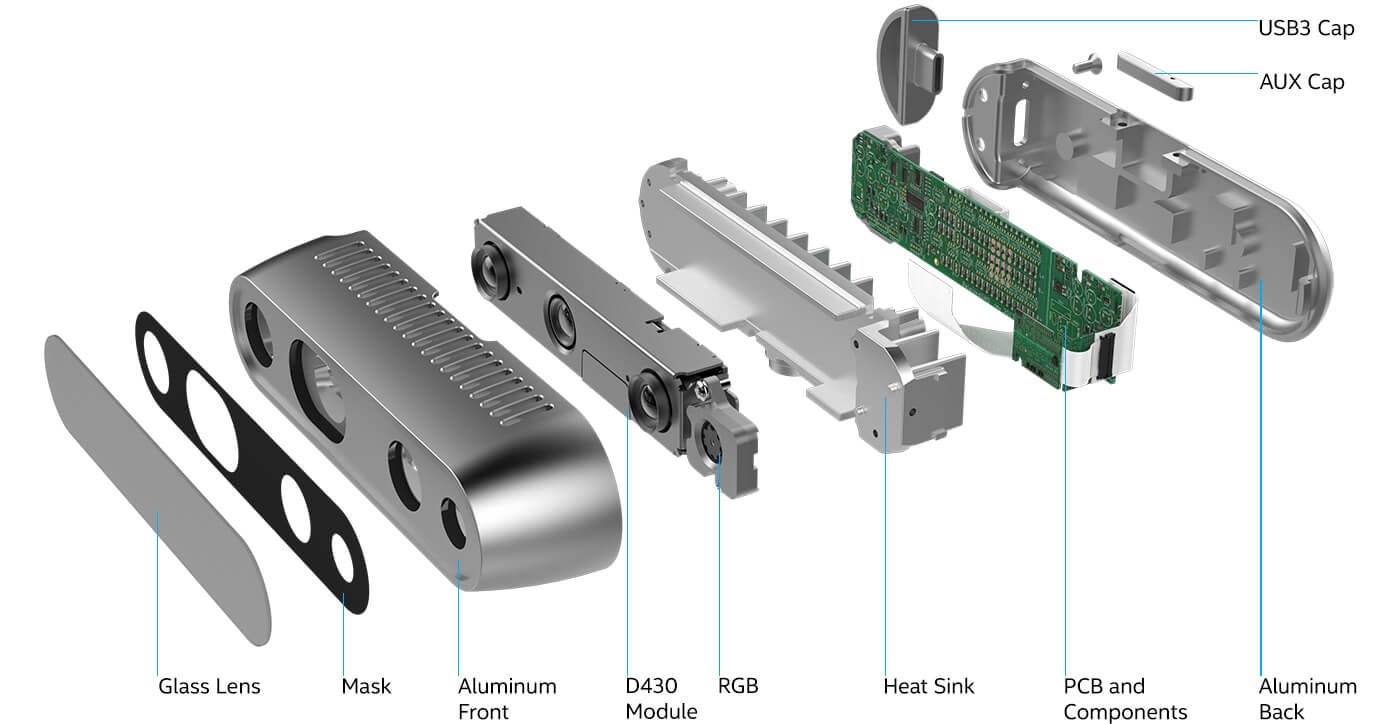
Aniket is a 2nd Year EECS + Business student. He's passionate about learning how to golf, watching F1 and cars. Worked on perception, portions of the control / planning pipeline, and helping test.
Micah is a senior Mechanical Engineering student. Worked on testing and debugging the system.